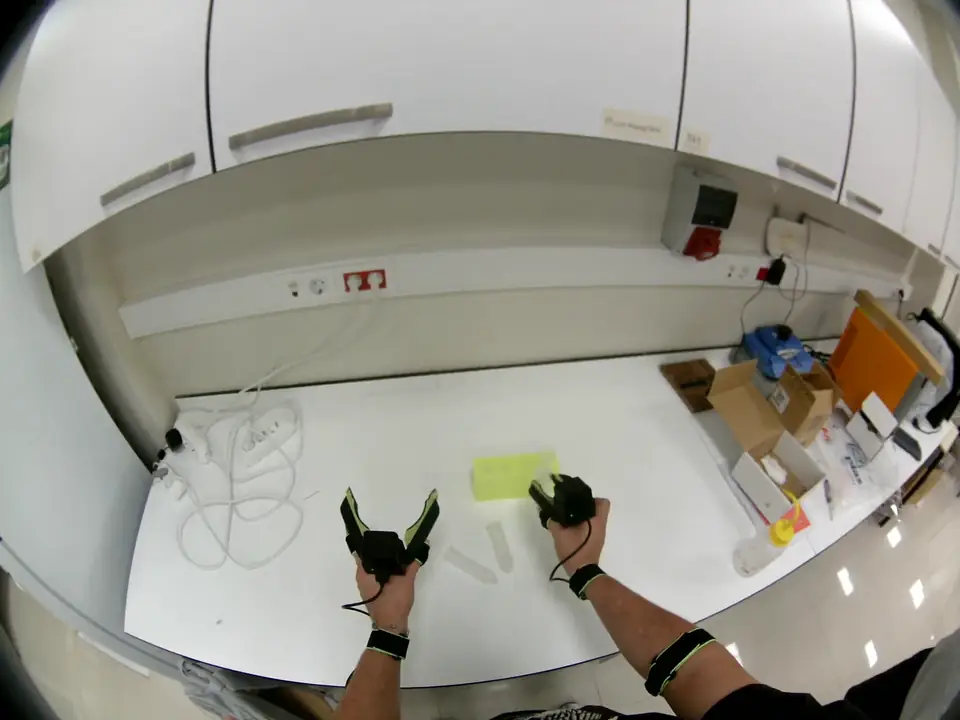
Video
Egocentric video
First-person stereo footage from two head-mounted cameras.
MP4
Human demonstration data
Real manipulation tasks recorded from four synchronized views. Each episode is labelled, segmented and aligned on one timeline.
01Capture
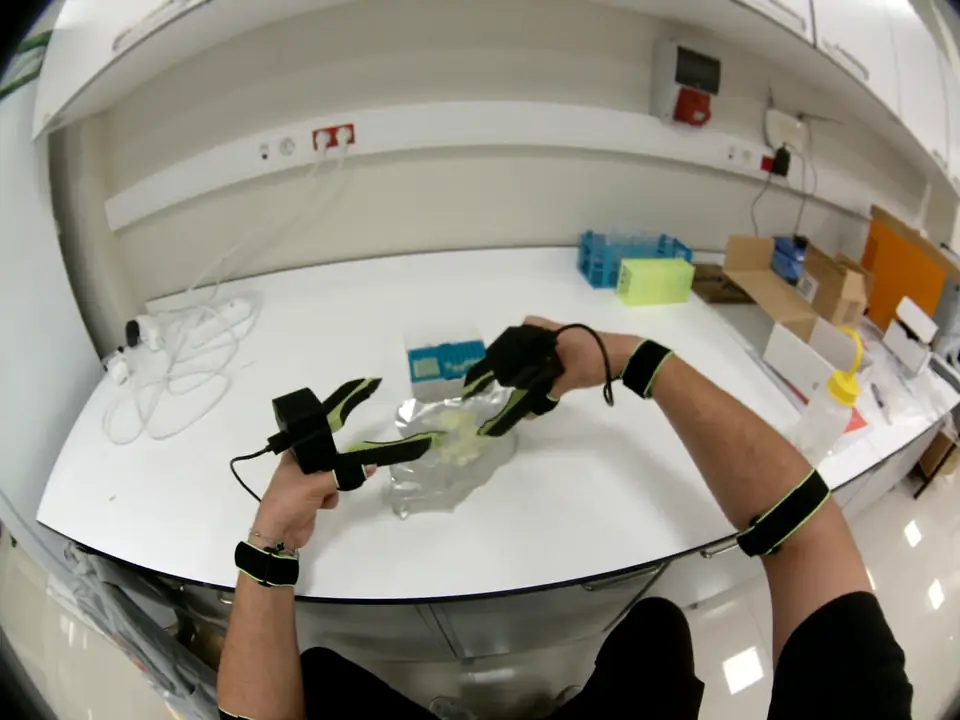
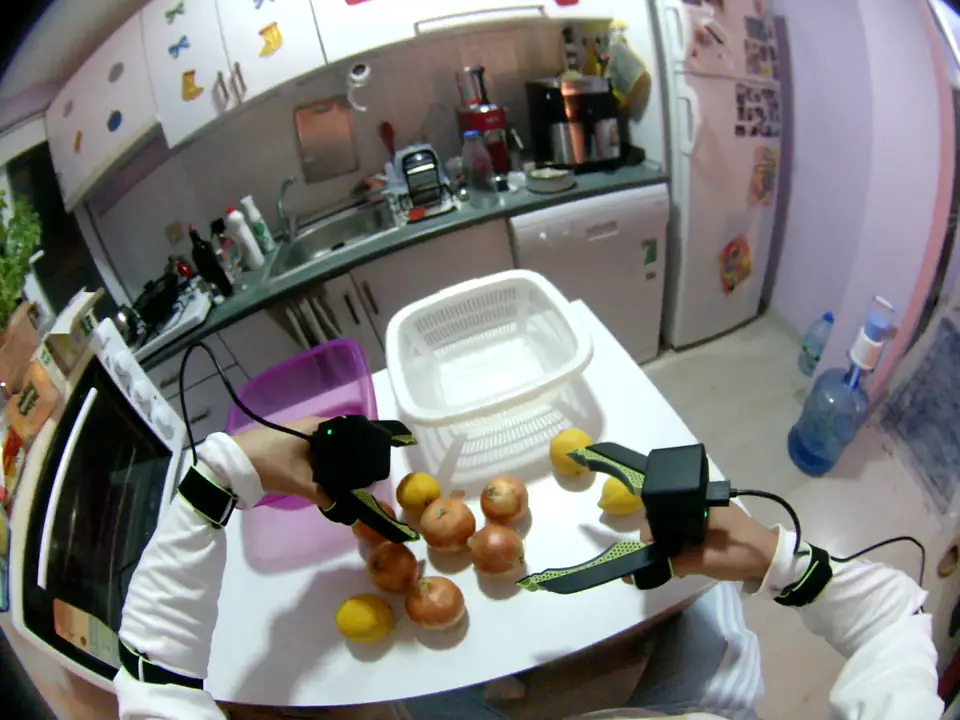
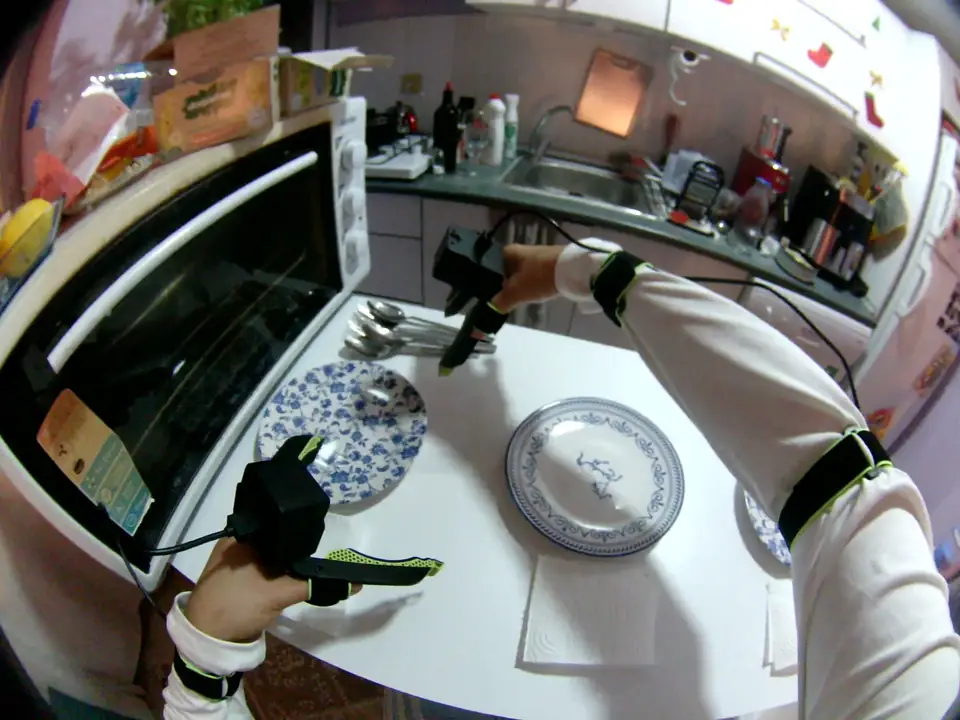
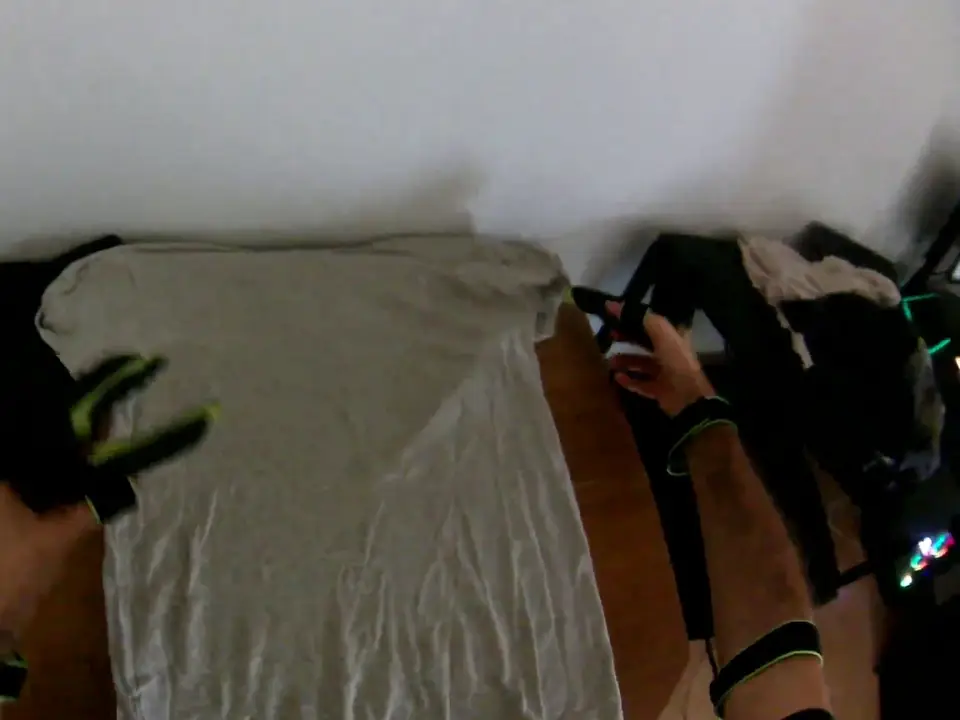
A person performs the task wearing a stereo head camera and holding two UMI-style grippers, each with its own camera.
Stereo egocentric head cameras plus a camera on each gripper. Every moment is recorded from all four at once.
Demonstrations use handheld UMI-style grippers. Motion is captured in end-effector space, so the data is not tied to a specific robot.
Lab benches, kitchens and homes. Real workspaces, not staged sets.
02Structure
Observations, sensor records and annotations are aligned in time. Below are six seconds of a real garment-handling episode, lane by lane.
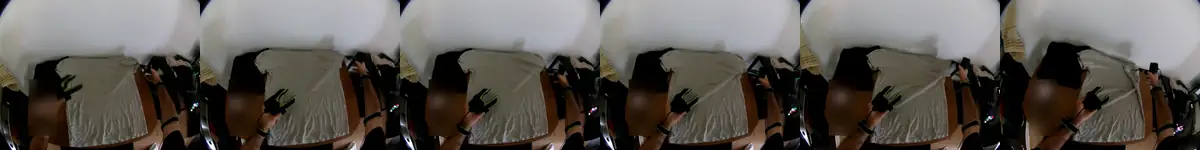
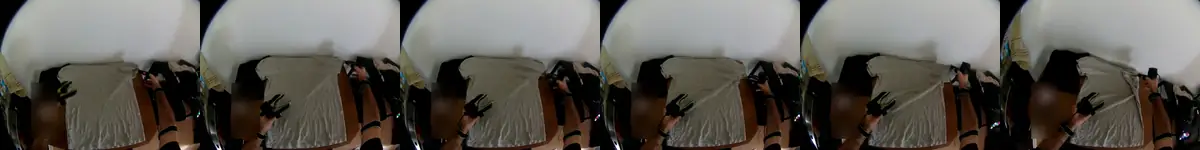
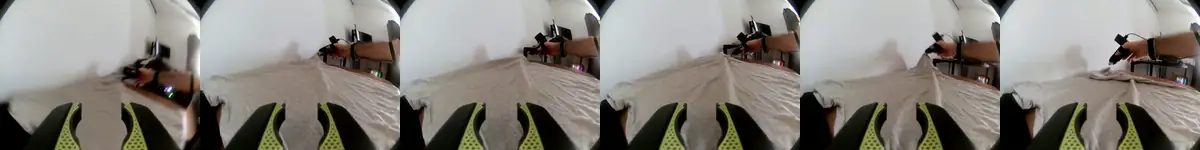
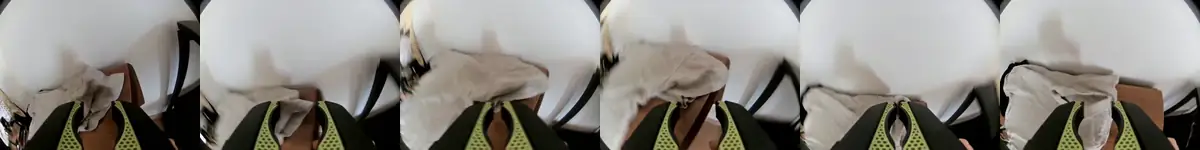
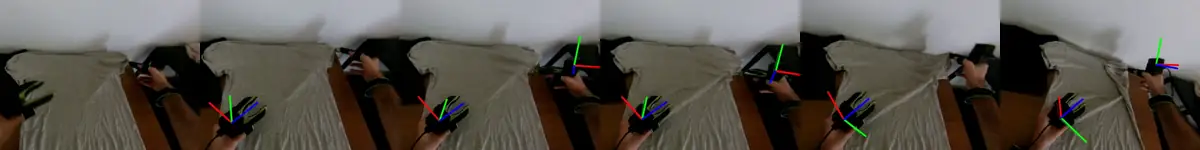
Frames shown at one-second intervals from ~30 Hz recordings. Pose is derived in postprocessing and included where available.
03Data types
Six data types across four layers, delivered together for each episode.
Video
First-person stereo footage from two head-mounted cameras.
MP4
Video
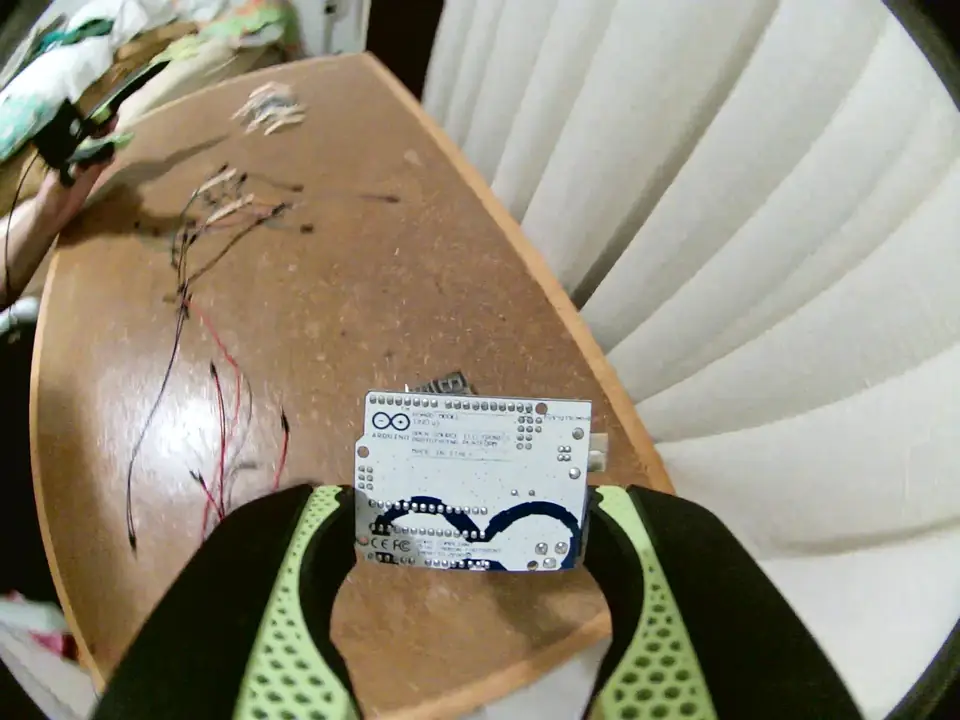
Close-up views from cameras mounted on the left and right gripper.
MP4
Motion
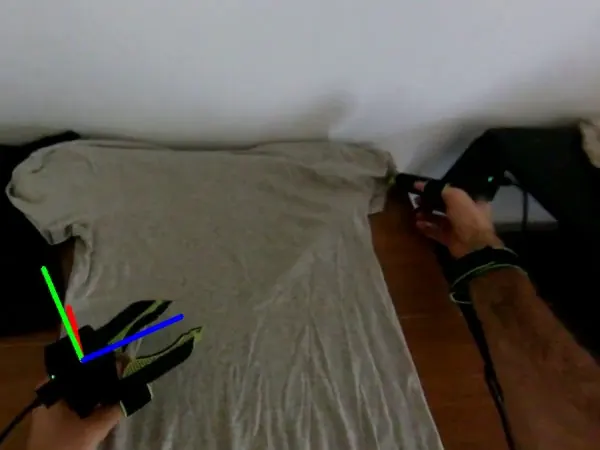
Gripper position and orientation over time, derived in postprocessing. Included where available.
Postprocessed
TaskLaboratory handling
Annotations
Each episode is labelled with its task. Steps such as reach, grasp and place are segmented on the timeline.
JSON
Instruction
“Place the test tube in the rack.”
Annotations
A short natural-language instruction for each episode.
JSON
Raw · MCAP
Sensor records
The original MCAP recordings, kept alongside the processed data.
MCAP
04Task categories
Each family has a representative sample episode. New collection is scoped around your objects and environments.
Placing tubes into a rack at a lab bench.
Pipette tips, packets and racks handled with both grippers.
Sorting produce into containers on a kitchen table.
Picking up and placing plates and cutlery.
Arranging boards, wires and small components.
Unfolding, aligning and folding a shirt with both grippers.
05Buying
Inspect a representative sample first. Then we scope the collection around your objects, environments and learning pipeline.
Tell us the task you care about. We send a representative episode.
Review the views, fields and delivery structure in your own tools.
Agree on objects, environments, variations and the format your learning pipeline reads.
Exports carry recorded observations and annotations. Mapping to robot-control actions is scoped per project.
Request a sample episode and tell us about the task. We scope the collection from there.